Outline
Operation
• ECM detects the remote control lever position by the voltage signal sent from the lever position sensor which is built in the remote control box.
ECM receives the lever position sensor signal through BCM and drives the actuator motor so that the actual clutch lever (gear) position agrees with the detected target shift position (lever position voltage signal). Thus, gear shifting to forward, neutral or reverse is performed.
The actual shift position is checked by the shift position sensor detecting it and is feed back to ECM.
• When a failure is detected in the system components, the shift motor relay is turned off causing the shift actuator drive to be interrupted.
• When the remote control box is replaced, the setting change should be performed using SDS Ver. 8.20.
• When ECM is replaced, BCM initialization and the system calibration should be performed using SDS Ver. 8.20.
• The shift change can be done by remote control lever only when ECM receives signal of engine turning.
The shift change can not be done by remote control lever during engine stopping even main switch is ON position.
• When engine is stopped, ECM controls the shift actuator to shift in neutral regardless the position of remote control lever.
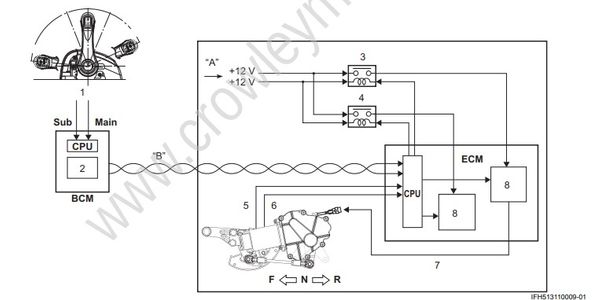
- LPS signal (main and sub)
- CAN driver
- ESA motor relay
- ETV motor relay
- Shift position sensor signal
- Neutral switch signal
- ESA motor operating signal
- Motor driver
“A”: From main relay
“B”: CAN communication